Pose Lab
Measured spatial answers for posing first-person arms and a rifle in Blender
Runs on your machine from its package; the steps are below.
What it does
- Reads
- Writes
- High impact
Not assessed yet.
What it costs
FreeOdel charges nothing per call. The publisher may charge for its own service.
Runs locally over stdio
This server isn't hosted — your MCP client launches it from a package registry. Use one of the commands below, or drop the config into your client (e.g. Claude Desktop).
Run
uvx poselab-mcp
MCP client config
{
  "mcpServers": {
    "pose-lab": {
      "command": "uvx",
      "args": [
        "poselab-mcp"
      ]
    }
  }
}Measured spatial answers for posing first-person arms and a rifle in Blender, over MCP.
Models are weak at judging 3D space from pictures: which side of a rifle faces the eye, whether a finger sits inside the receiver, whether any turn of the gun can ever show its ejection port. Pose Lab gives a model numbers instead. It reports positions in named frames and how deep anything clips. It measures how squarely a surface faces the eye and what the eye can see. Its solver searches rifle moves against goals and reports which goals no move can meet. For animation, it scans a clip frame by frame against the same checks and mends what fails.
I built it while hand-making chamber checks for my first-person shooter. One question took me several full Blender
runs: can turning the rifle show its ejection port to the eye? With Pose Lab it is one solve call. On my game's AK
rig, turning alone met the goal in 0 of 60 samples. That is a fact of the geometry: the eye looks along the barrel.
Turning and moving the rifle met each goal on its own, but no sample of 400 met all four goals together. So that
check needs a new hand pose, not only a new rifle position. On the built-in sample rig, turning alone also met the port
goal in 0 of 60 samples, and turning and moving met every goal in 9 s.
What it gives a model
| Tool | Answers |
|---|---|
list_rigs, load_rig, describe | the rigs, the frames, the sign rules, named points, clips, moving parts |
pose_idle, pose_clip, move_part, snapshot | put the rig in a pose: a clip at a time, the carrier drawn back, saved poses |
move_gun | roll, swing, pitch and move the rifle; the hands keep their hold by arm IK |
reach | a wrist onto a point by arm IK (try elbow poles to clear a forearm) |
where, distance | positions in a named frame |
clearance | how deep the rifle sits inside a forearm, palm or finger, measured to its surface, and where |
anatomy | each arm against the human arm's limits: elbow, wrist and each finger joint, and every rule a pose breaks |
grip | how each hand touches the rifle: with the palm, not the back of the hand; whether the palm itself holds it; how deep on each side |
arm_ranges | the research behind those limits: each joint's AAOS range, its functional range, the value checked, and the sources |
faces_eye, visible, screen | how squarely a surface faces the eye, how much of it the eye sees, where it falls on screen |
solve | searches rifle moves against goals; reports each goal and how often any sample met it |
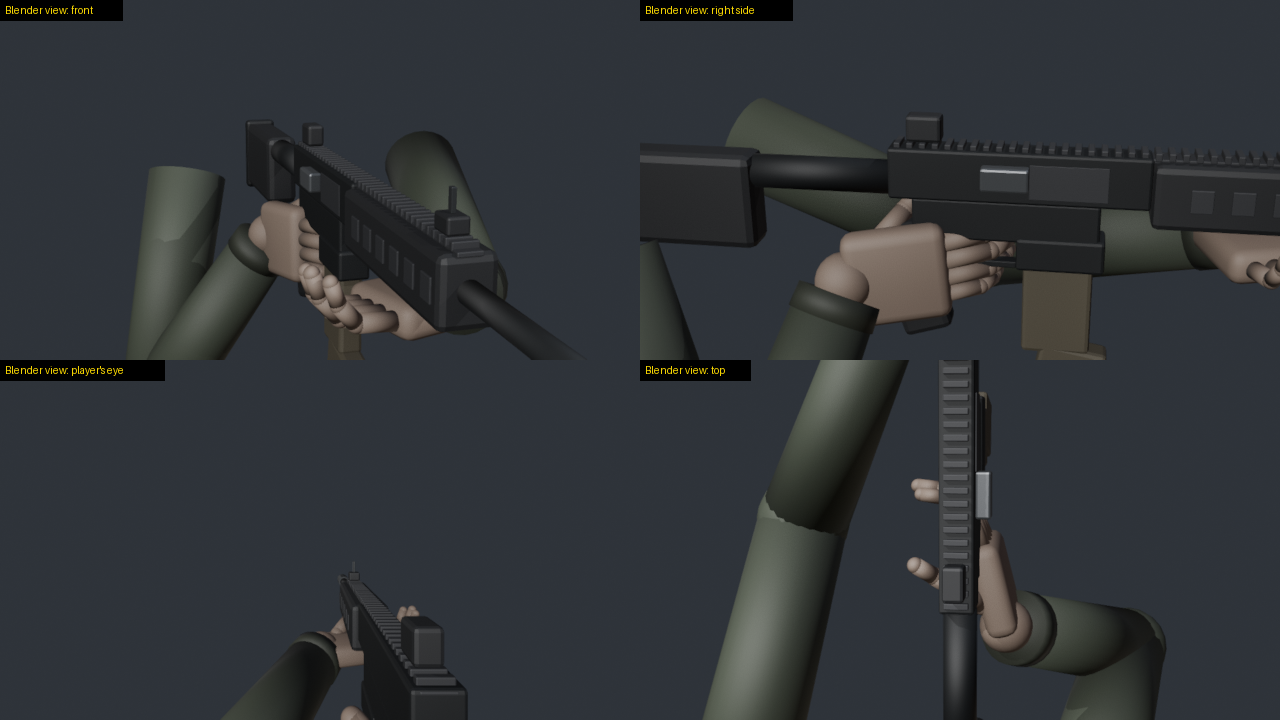
render | a contact sheet: the player's eye and outside views, each tile labelled as a Blender view |
record_clip, load_clip | a clip from keyed poses, or from a file: .pose.json, FBX or BVH |
scan_clip | every frame against checks; the worst value, when, and the time spans that fail |
fix_clip | mends what fails and reports the scan before and after, and what no fix can reach |
save_clip | writes a clip as .pose.json bone data and as FBX for a game engine |
Frames and signs
Every position goes in and comes out in a named frame, so no one has to guess axes:
gun: the gun bone as it stands, Unreal-style axes, cm: +X the gun's left, +Y along the barrel, +Z up (the default)arms: the arms' space, Unreal-style axes, cmview: from the eye, cm: +X right, +Y forward, +Z up
Turns use the player's words: roll + turns the gun's right side up, swing + takes the muzzle left, pitch + the
muzzle up. Moves (right, forward, up) are in the view.
A hand round its grip touches the rifle on the idle pose already (a finger on the trigger, fingers round the
handguard). Call clearance at pose_idle for that baseline, and leave those segments out with ignore wildcards.
On the built-in sample the left thumb sits 2.7 cm inside the handguard at idle. clearance measures to the rifle's
surface (inside or out by ray parity), so it sees a body part inside a flat face between the mesh's corner points.
Arm rules (anatomy)
A pose can clear the rifle and still be one no human arm can take. anatomy checks each arm against these limits:
| Joint | Rule |
|---|---|
| Shoulder | the elbow stays at least 2 cm below the shoulder while the hand works the gun |
| Elbow | a hinge, bent 5 to 150 degrees: never locked straight |
| Forearm | it carries the hand's roll (the radius turns over the ulna): pronation and supination at most 80 degrees each from thumb up, measured against the elbow's hinge plane |
| Forearm skin | on a rig with forearm twist bones, the roll spreads along the forearm: no single link (the elbow's end, each twist bone, the wrist) rolls more than 50 degrees |
| Wrist | no twist of its own; on a rig without twist bones, the hand's twist against the idle grip's at most 30 degrees |
| Wrist | within 30 degrees of the forearm's line; inside its joint range: flexion 80, extension 70, radial 20, ulnar 30 |
| Fingers | each joint curls only toward the palm: knuckle -30 to 100, middle joint -5 to 110, end joint -10 to 90 |
| Fingers | each finger stays in its own plane: the middle joint at most 15 degrees off its hinge, the end joint at most 25 off the middle joint's plane |
| Thumb | the knuckle bends -10 to 60 and the end joint -15 to 90, across the palm; the base spreads at most 80 from the index metacarpal and sits at most 20 behind the palm |
The wrist and elbow ranges are the AAOS normal values, from the AAOS 1965 table as reprinted in Greene and Heckman
1994. Other tables differ, by 10 to 25 degrees for the fingers and thumb. The 30 degree wrist line, the 5 degree elbow
minimum and the elbow under the shoulder are working rules for this game's look of a hand on a gun, not joint limits.
The wrist rule is stricter than daily tasks: Ryu 1991 found daily tasks use up to 60 degrees of extension and 40 of
ulnar deviation. The finger limits allow 10 more flexion than AAOS at the knuckle and the middle joint;
docs/ANATOMY.md says why the defaults stay that way. It gives each joint's standard and functional
range, the value checked, and the sources (AAOS; Eaton; Morrey 1981; Palmer 1985; Ryu 1991; Hume 1990; Bain 2015;
Soucie 2011). arm_ranges returns the same data to a model.
The anatomy reply lists, for each arm, the elbow's height under the shoulder, the elbow's bend, the wrist's bend split into
flexion and radial deviation, the wrist's twist, each finger joint's curl and twist, and bad: every rule the pose
breaks. Each rule reads the value as reported: angles to the degree, the elbow's height to 0.1 cm. A rig's
limits, finger_limits and thumb_limits entries in rigs.json override any value. solve takes {"type": "anatomy"} as a goal.
move_gun, reach and fix_clip place hands with a turn. They move the hand's twist into the forearm, so the wrist
joint only bends: a 60 degree rifle roll with the hands kept reads no wrist twist.
Fix a broken rule by moving the rifle, the grip or the elbow's pole. Do not bend a joint further.
The sample rig's idle grip breaks the wrist rule: the left wrist bends 44 degrees off the forearm and the right 58.
fix_clip with an anatomy check brings the left to 29. It leaves the right at 58: every turn that mends it puts
the rifle inside the back of the palm, so that hand needs a new grip or elbow, not a wrist turn.
Hand contact (grip)
A hand holds the rifle with its palm and the palm sides of its fingers. clearance is usually run with the palms and
fingers left out, since a grip touches the rifle there. That also hides a hand on the wrong side. grip checks the
contact itself, for each hand:
| Rule | Default |
|---|---|
A hand on the rifle faces it with the palm, not the back (palm_faces_rifle above 0) | within hold_within_cm 1.0 |
A hand holding the rifle has its palm on it, not only a fingertip (palm_gap_cm) | palm_within_cm 1.5 |
| The rifle stays out of the back of the hand and the back of each finger | back_max_cm 0.1 |
| The palm side may press in a little: the capsules are rounder than a palm | palm_max_cm 1.0 |
Each finger segment's palm side is the side it curls toward. The thumb's pad faces sideways, so its contacts count
toward the palm side's depth only. The reply gives each hand's touching (some part within hold_within_cm),
holding (touching, the palm facing the rifle and its surface within palm_within_cm), palm_gap_cm,
palm_faces_rifle, palm_contact_cm, back_contact_cm, where the back contact is, and bad. With hold true, a hand
that is not holding breaks a rule. solve takes {"type": "grip"} as a goal and scan_clip as a check. On the sample
rig, a hand turned 180 degrees about its forearm fails it. So does the idle grip: the left thumb sits 2.8 cm inside the
handguard, the right palm presses 1.2 cm into the pistol grip, and the trigger finger's back sits 0.8 cm inside the
trigger guard. The sample stays as it is, so the benchmark's numbers keep their meaning.
Motion: scan and fix clips
scan_clip plays a clip frame by frame and runs checks on each frame. The checks are the solver's goals
(clearance, anatomy, grip, faces_eye, visible, on_screen, barrel) and three more:
contact: a point of the hand on its mark, such as a fingertip on the charging handle (a,b,max_cm)hold: how far a hand drifts on the rifle from its grip atref_s(side,max_cm)pop: a sudden jump, as the fastest bone speed between frames (bones,max_cm_per_s)
Any check takes during: [from_s, to_s]. fix_clip then mends a copy of the clip:
- a pop: it blends the jumping frames again from the good frames round them
- a hold: it puts the hand back on its grip by arm IK
- a contact: it moves the wrist until the point touches its mark
- clearance: it swings each elbow about the shoulder to wrist line by the least angle that clears, wrist kept, and eases that swing over the neighbouring frames
- anatomy: it swings the elbow the same way until the elbow sits under the shoulder and inside its bend. Then it turns
the wrist back inside its limits and each finger joint back inside its range. It never turns a wrist so far that
the rifle goes into the back of the hand; a wrist it cannot mend that way stays as it was, and the scan after says
so. Turning the wrist turns the hand on its grip, so add a
holdcheck when the grip must stay exact. - grip: not mended;
fix_clipreports it before and after. A wrong-side hold needs a new grip.
It reports the scan before and after. It also lists the frames where a hand must be somewhere its arm cannot reach, since only a new pose can mend those.
examples/motion_test.py records a clip on the sample rig with two common faults. The rifle rolls 75 degrees and
back, keyed only at its ends, so the hands drift off the rifle between keys. One frame also jumps 15 cm. The scan and
the fix gave these numbers:
| Check | Before | After |
|---|---|---|
| left hand drift on the rifle | 2.27 cm | 0.48 cm |
| right hand drift on the rifle | 1.67 cm | 0.45 cm |
| fastest hand speed (the pop) | 450 cm/s | 33 cm/s |
| clearance | 0.93 cm | 0.0 cm |
The fix changed 34 of 43 frames, and every check passed after it. It also flagged 6 frames where the left arm fell 0.46 cm short of its grip. That still passed the 0.5 cm limit. (Before 0.3.1 the clearance read 0.0 cm: the corner points missed the forearm inside the rifle.)
Install
You need Blender and Python 3.10 or newer. I tested it on Windows 10 with Blender 5.2.2 and Python 3.14. I have not tested macOS, Linux or older Blender versions yet.
uvx poselab-mcp
or pip install poselab-mcp and run poselab-mcp.
Add it to Claude Code:
claude mcp add poselab -- uvx poselab-mcp
or to any MCP client's configuration:
{
  "mcpServers": {
    "poselab": {
      "command": "uvx",
      "args": ["poselab-mcp"],
      "env": { "POSELAB_BLENDER": "C:/Program Files/Blender Foundation/Blender 5.2/blender.exe" }
    }
  }
}
Settings
| Variable | Meaning |
|---|---|
POSELAB_BLENDER | Blender's executable, if it is not on the PATH or in the usual install folder |
POSELAB_RIGS | a rigs.json describing your own rigs (see examples/rigs.example.json) |
POSELAB_OUT | the only folder Pose Lab writes to (renders, saved clips, the worker's log); default ~/.poselab |
Rigs
The built-in sample (load_rig {"rig": "sample"}) needs no files. Pose Lab builds it in Blender from code: two
arms with Unreal mannequin bone names hold an AR-style rifle with a charging handle that slides back.
Your own rigs come from FBX files: the arms mesh, an idle pose, the rifle, and clips. Describe them in a
rigs.json (copy examples/rigs.example.json) and point POSELAB_RIGS at it. Clips can be FBX animations on the same
skeleton, or <clip>.pose.json bone data: {"fps": 30, "frames": [{"bone": [[x, y, z], [w, x, y, z]], ...}, ...]},
local location and rotation per bone on the idle armature. (Blender misreads an FBX animation it exported itself when
it imports it again; bone data avoids that. describe reports each FBX clip's skeleton fit.)
Safety
- Pose Lab only reads your rig and clip files. It writes renders, saved clips and its log, and only inside
POSELAB_OUT. - The Blender worker listens on 127.0.0.1 only, on a free port, and answers only requests that carry the session's random token. It runs only Pose Lab's own commands.
How it works
poselab_mcp/server.py: the MCP server (the official Python SDK, stdio).poselab_mcp/worker_client.py: starts one headless Blender on the first call and keeps the rig loaded.poselab_mcp/blender/lab.py: inside Blender: the rig, the frames, the measures, the IK, the solver, the renders.poselab_mcp/blender/sample.py: the built-in sample rig.
Test
python examples/selftest.py
It starts the server as an MCP client does and loads the sample rig. Then it replays the question above: turning
alone never shows the port, and turning and moving does. The contact sheet lands in ~/.poselab/renders/sheet.png.
python examples/motion_test.py
It records the faulty clip described above, scans it, fixes it, and saves roll_fixed.pose.json and roll_fixed.fbx
in ~/.poselab/clips/.
blender -b -P examples/anatomy_faults.py
It puts one known fault at a time on the sample and fails if a check misses it: a finger kinked sideways, a hand twisted against its forearm, a hand inside a flat face, a fingertip-only touch, and a rigs file with a byte order mark. These come from a real rig's benchmark (below).
Benchmark
benchmarks/ asks whether a model poses the rig better with Pose Lab's measurements than with renders alone. It runs
five tasks on the sample rig and grades them with Pose Lab. A scripted oracle and a do-nothing control check the
graders. See benchmarks/README.md.
benchmarks/runs/2026-10-09-toangtown-m24 tests the checks themselves on a real game rig: 8 poses of a hand on a magazine, 7 with a known fault. Pose Lab 0.3.0 caught 5 and read clipping at 40% of its depth; 0.3.1 catches all 7 with the depths exact.
License
MIT