Isaac Sim robot workbench
Drive a live Isaac Sim session: any robot, poses, gain tuning, range tests, Isaac Lab training.
Runs on your machine from its package; the steps are below.
What it does
- Reads
- Writes
- High impact
At most: moves money, runs code or commands, deletes data, or sends messages for you.
What it costs
FreeOdel charges nothing per call. The publisher may charge for its own service.
Runs locally over stdio
This server isn't hosted — your MCP client launches it from a package registry. Use one of the commands below, or drop the config into your client (e.g. Claude Desktop).
Run
uvx dex-isaac-mcp
MCP client config
{
  "mcpServers": {
    "isaac-sim-robot-workbench": {
      "command": "uvx",
      "args": [
        "dex-isaac-mcp"
      ]
    }
  }
}dex-isaac-mcp
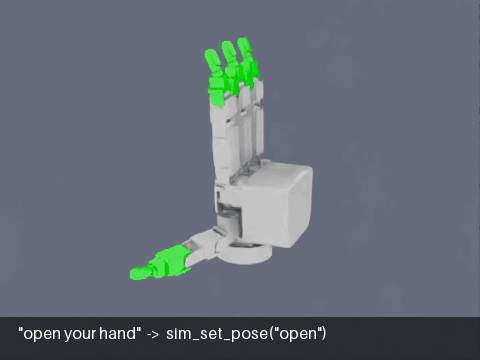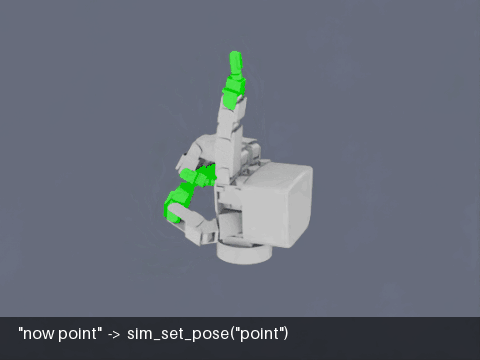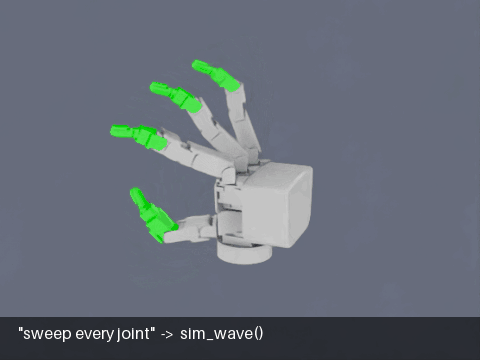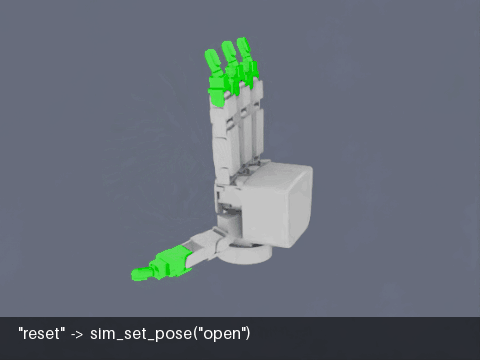
Recorded headless with the server's own tools (sim_frame_robot, sim_set_backdrop, sim_record_start), driving the Allegro hand example. Each caption is the request and the tool call it became.
An MCP server that lets an AI agent (Claude Code, or any MCP client) drive a live, persistent Isaac Sim session and launch Isaac Lab training runs.
Kit takes tens of seconds to boot. If every experiment is a fresh launch, most of your time goes to waiting. Here Kit starts once inside a daemon and stays up. Each tool call lands in that running session, so changing a gain, stepping physics or taking a screenshot costs a frame, not a relaunch.
 MCP client ──stdio──▶ dex_isaac_mcp (host, plain python)
                          │  newline-delimited JSON over a Unix socket
                          ▼
                       scripts/simd.py (Isaac Lab container, Kit stays up)
                          └─ one articulation, described by a robot JSON
- Any articulated robot. Point it at a USD and a small JSON config. Franka and Allegro examples are included.
- Normalized joint control. Targets are
0..1, where 0 is a joint's lower limit and 1 its upper limit, so agents don't need to know radians or meters. - Named poses per robot (
home,fist, …), which can be blended part-way. - Headless capture and GIF recording from an auto-framed camera, with captions. The clip above was made this way.
- Props: spawn a table, a ball or a USD into the running scene and read back where they settle.
- Measurements: joint state, per-joint travel and tracking error, a range test that finds blocked joints, and parameter sweeps inside one session.
- Training control: each run is a detached
docker compose run. You can poll its status, TensorBoard scalars, checkpoints and logs.
How it differs from other Isaac Sim MCP servers
NVIDIA's official Isaac Sim MCP is a documentation search for coding assistants, and works well alongside this one. Servers like isaacsim-mcp-server and omni-mcp/isaac-sim-mcp run inside the Isaac Sim GUI and cover scene building broadly. This one runs headless, as a daemon in Docker, and focuses on tuning, measuring and training one robot.
| NVIDIA Isaac Sim MCP | In-GUI servers (isaacsim-mcp-server, omni-mcp) | dex-isaac-mcp | |
|---|---|---|---|
| What it is | Docs and code search | Kit extension inside a running Isaac Sim | External daemon; Kit stays up in a container |
| Controls the simulation | No | Yes | Yes |
| Headless / remote GPU box | n/a | Needs the GUI | Yes: headless capture, Docker, Unix socket |
| Scene building (lights, materials, sensors, asset library) | n/a | Broad | Minimal: primitive and USD props |
| Robot setup | n/a | Built-in robot library | Any USD plus a small JSON config (joints, poses, couplings, gains) |
| Measurement | n/a | Joint and prim state | Range tests that find blocked joints, tracking error, sweeps that restore the original value |
| Live tuning | n/a | Not documented | PD gains, effort, software mimic couplings |
| Isaac Lab training | n/a | Not documented | Launch, poll, TensorBoard metrics, checkpoints, stop |
| Recording | n/a | Camera captures | Captioned GIFs from an auto-framed camera, headless |
| Platform | Any | Wherever Isaac Sim runs | Linux, NVIDIA GPU, Docker, NGC |
Pick an in-GUI server to build a scene by talking to it, interactively, with a wide robot and asset library.
Pick this one to have an agent tune, debug and train a specific robot (your own, from a USD), unattended or on a remote box, with numbers it can act on instead of only screenshots.
Requirements
- Linux with an NVIDIA GPU that Isaac Sim supports, plus the NVIDIA Container Toolkit
- Docker with the Compose plugin
- An NGC login to pull the Isaac Lab image:
docker login nvcr.io(user$oauthtoken, password: your NGC API key) - Python ≥ 3.10 on the host, for the MCP server only
Quick start
git clone <this repo> dex-isaac-mcp && cd dex-isaac-mcp

# 1. Build the image (Isaac Lab 2.3.2 base, pinned by digest)
cd docker && docker compose build && cd ..

# 2. Install the host-side server, editable so it finds this clone
pip install -e .            # add [metrics] for train_metrics: pip install -e '.[metrics]'

# 3. Register it with Claude Code
claude mcp add isaac -- python -m dex_isaac_mcp

# 4. Allow the container to open windows (once per login; needed for screenshots)
xhost +local:docker
Then ask the agent something like "start the sim with the Franka, move it to ready and show me a screenshot." It will call sim_up, sim_set_pose, sim_step and sim_screenshot.
From PyPI instead: pip install dex-isaac-mcp. The daemon still runs from a clone (it needs docker/ and scripts/simd.py), so point the server at it:
claude mcp add isaac -e ISAAC_MCP_HOME=/abs/path/dex-isaac-mcp -- dex-isaac-mcp
Other MCP clients can launch python -m dex_isaac_mcp (or the dex-isaac-mcp script) over stdio.
The first sim_up takes several minutes: Kit builds its shader cache and downloads Nucleus assets. Later starts are much faster.
Running the daemon by hand
sim_up deletes its container (--rm) when the daemon exits, so a crash on startup takes its traceback with it. To see the error, run the daemon in the foreground:
cd docker
docker compose run --rm simd scripts/simd.py --gui --robot examples/robots/franka.json
docker compose run --rm simd scripts/simd.py --headless --usd /path/in/container/robot.usd
docker compose run --rm simd scripts/simd.py --sliders --robot examples/robots/allegro_hand.json
--sliders opens an omni.ui panel with one slider per driven joint. The socket stays live alongside it.
Tools
Session
| Tool | What it does |
|---|---|
sim_status | Whether the daemon is up, plus its robot, driven joints, poses, couplings and gains |
sim_up | Start the daemon container (robot, usd, gui, ground, extra_args) and wait until it answers. Does nothing if it is already up |
sim_down | Stop the daemon |
sim_reload | Restart with a different spawn property: robot, USD, pos_iters, self-collision |
Inspect
| Tool | What it does |
|---|---|
sim_inspect_joints | A USD's articulation DOFs, its loop-closure joints (excluded from the articulation) and its articulation roots. Reads the file, so it shows edits saved from the GUI |
sim_get_joint_state | Positions and velocities, plus driven joints' normalized positions and limits |
sim_get_stats | Per-joint travel and mean tracking error since the last reset |
sim_screenshot | Viewport capture, returned as an image. Needs gui=True |
sim_set_camera | Point the viewport camera |
Drive
| Tool | What it does |
|---|---|
sim_set_targets | Normalized targets, as a full vector or {joint: value} |
sim_list_poses / sim_set_pose | Named poses from the robot config. amount blends toward a pose, starting from the lower limits or from the current targets |
sim_step | Advance N physics steps (default dt 1/120 s) |
sim_play | Run continuously, or pause |
sim_wave | Sweep every driven joint through its range and return travel stats |
sim_range_test | Drive every joint from its lower limit toward a target and report the fraction of travel reached. Below 0.9 counts as blocked (self-collision, a binding linkage, too little effort) |
Scene
| Tool | What it does |
|---|---|
sim_spawn_object | Add a prop to the live scene: cuboid, sphere, cylinder, capsule, cone or a USD file, with collision. static for a fixed table or wall, kinematic for a body contact cannot move |
sim_list_objects | Every prop's current world pose |
sim_remove_object | Delete a prop |
Capture and record
These work headless, with no GUI or viewport. They use a dedicated camera that is independent of the GUI view.
| Tool | What it does |
|---|---|
sim_frame_robot | Aim the capture camera so the whole robot fills the frame, from a given direction. raise_frac leaves room for captions |
sim_set_capture_camera | Place the capture camera by hand |
sim_set_backdrop | A plain colored panel behind the robot. Use it with ground=False for clean footage |
sim_capture | One frame, returned as an image |
sim_record_start / sim_record_caption / sim_record_stop | Record every Nth physics step, with a caption drawn on each frame, to an animated GIF under .cache/recordings/. Anything that steps the sim is recorded |
Tune
| Tool | What it does |
|---|---|
sim_set_params | Live stiffness / damping / effort on the driven joints |
sim_set_coupling | Live software-mimic ratios, keyed by follower joint |
sim_sweep | Try several values of one live parameter (stiffness, damping, effort, coupling:<follower>), running wave or range for each. Restores the original value afterwards. A diverging solver is recorded as a result rather than raised |
Train
| Tool | What it does |
|---|---|
train_start | Launch a headless training run in its own container and return at once. extra_args go to the script verbatim (e.g. Hydra overrides). device pins a GPU |
train_list | Running and recent runs, and log directories holding checkpoints |
train_status | Container state, checkpoints and latest scalars |
train_logs | Tail a running container's output |
train_metrics | List TensorBoard tags, or get a downsampled series for one tag |
train_checkpoints | Checkpoints with step and size |
train_stop | Stop a run |
Training runs do not depend on the daemon or on the MCP session. They keep going after the client disconnects.
Robot config
A robot is one JSON file. Only usd is required. Unknown keys are rejected, so a typo fails loudly instead of quietly falling back to a default.
{
  "name": "franka",
  "usd": "{ISAACLAB_NUCLEUS_DIR}/Robots/FrankaEmika/panda_instanceable.usd",
  "fix_root_link": true,
  "spawn_pos": [0, 0, 0],
  "init_joint_pos": {"panda_joint4": -2.81, "panda_joint6": 3.04, ".*": 0.0},
  "driven_joints": ["panda_joint[1-7]", "panda_finger_joint.*"],
  "passive_joints": [],
  "couplings": [{"leader": "joint_a", "follower": "joint_b", "ratio": 1.0}],
  "actuator": {"stiffness": 400, "damping": 40, "effort": 87, "velocity": null},
  "solver": {"pos_iters": 32, "vel_iters": 4, "self_collisions": true},
  "camera": {"eye": [1.8, 1.8, 1.4], "target": [0, 0, 0.4]},
  "poses": {"ready": {"panda_joint[1357]": 0.5, "panda_finger_joint.*": 1.0}}
}
| Key | Meaning |
|---|---|
usd | Local path (relative paths resolve from the JSON's own directory), a URL, or a path using {ISAAC_NUCLEUS_DIR} / {ISAACLAB_NUCLEUS_DIR} |
init_joint_pos | Spawn pose in the joints' own units (rad / m), keyed by regex. It must lie inside every joint's limits or spawning fails. The default is all zeros, which is out of range for e.g. Franka's joint 4 |
driven_joints | Regexes (full match) for joints that take commands. Default .* |
passive_joints | Joints whose angle is owned by a constraint, such as a closed-chain linkage. They get a zero-stiffness drive, because a live PD drive fights the constraint and the mechanism jitters |
couplings | Software mimic joints: follower target = ratio × leader target. They are applied as drive targets rather than PhysX mimic constraints, so a large ratio cannot blow up the solver |
actuator | Implicit PD gains and effort/velocity limits for the driven joints. Live-tunable |
solver | Spawn properties. Changing them needs sim_reload |
poses | {name: {joint_regex: 0..1}}. Later patterns win, so {".*": 0, "thumb.*": 1} works. A pattern that matches no driven joint is an error |
Using your own robot without forking
Keep the robot config and assets in your own repo, and add them to the container with a compose override that you list in COMPOSE_FILE. Set it in the MCP server's environment, using absolute paths:
# my-robot/mcp-compose.yaml
services:
  simd:
    volumes:
      - /abs/path/my-robot:/workspace/my-robot
claude mcp add isaac \
  -e COMPOSE_FILE=/abs/path/dex-isaac-mcp/docker/docker-compose.yaml:/abs/path/my-robot/mcp-compose.yaml \
  -e ISAAC_MCP_ROBOT=/workspace/my-robot/robot.json \
  -- python -m dex_isaac_mcp
Training defaults
Out of the box, train_start runs Isaac Lab's stock skrl script inside the isaac-lab service. It tags the run name onto the log directory (logs/skrl/<experiment>/<timestamp>_ppo_torch_<run_name>/), which the other train_* tools use to find the run. To use your own launcher, set these in the environment the MCP server starts in:
| Variable | Default |
|---|---|
ISAAC_MCP_HOME | the clone this package was installed from (editable install); required for a PyPI install |
ISAAC_MCP_COMPOSE_DIR | <repo>/docker |
ISAAC_MCP_TRAIN_SERVICE | isaac-lab |
ISAAC_MCP_TRAIN_WORKDIR | /workspace/isaaclab |
ISAAC_MCP_TRAIN_SCRIPT | scripts/reinforcement_learning/skrl/train.py |
ISAAC_MCP_LOGS_DIR | <repo>/logs (mounted at /workspace/isaaclab/logs) |
ISAAC_MCP_RUN_NAME_ARG | agent.agent.experiment.experiment_name={run_name} (empty = don't pass one) |
ISAAC_MCP_TRAIN_ARGS | hydra.run.dir=/tmp/hydra hydra.output_subdir=null: appended to every run. The stock script otherwise writes Hydra's outputs/ into the root-owned /workspace/isaaclab and dies. Set it empty for a non-Hydra script |
ISAAC_MCP_SIMD_SERVICE | simd |
ISAAC_MCP_ROBOT | robot config sim_up loads when none is given (unset: Franka example) |
ISAAC_MCP_SOCKET | <repo>/.cache/simd.sock |
The script must accept --task, --headless and, when given, --num_envs, --seed, --max_iterations and --checkpoint. Tasks from your own extension need to be importable inside the container, either installed into the image or mounted.
Design notes
These are the constraints the code is built around. Most were learned by breaking them.
- Every Kit call happens on the main thread. Kit, PhysX and USD are not thread-safe. Socket threads only parse JSON and queue requests, and the main loop executes them between physics steps. Answering from a reader thread appears to work, then corrupts the stage under load.
- Spawn properties are frozen. Replacing a spawned articulation needs
SimulationContext.stop(), which blocks on a timeline event that only advances while the Kit loop pumps. A command runs on that loop, so the call never returns.omni.usdnew_stage()has the same trap. So the USD, solver iterations and self-collision need a restart (sim_reload), and gains stay live. - A Unix socket, not TCP. The repo is bind-mounted and the container runs as the host uid, so the host sees the socket file directly, with no port mapping. Paths are capped at 107 bytes (
AF_UNIX). If your checkout is deep, setISAAC_MCP_SOCKET. - The host side imports no Isaac code.
protocol.py,robot.pyandtraining.pyare stdlib-only. The MCP server adds onlymcp. Nothing on the host needs isaaclab, torch or a GPU. - Cache directories are committed with
.gitkeep. If Docker auto-creates a bind-mount source, it is root-owned, and Kit then dies withregistry cache path is not setbefore any script runs. - The base image is pinned by digest. A re-pulled tag once shipped
/isaac-simas mode 750, and every non-root container lost its Python. - Recorded GIFs are stabilized. The renderer's denoiser shimmers: between two frames of a motionless scene, about 9% of background pixels change slightly, and a GIF re-encodes every one of them. Holding sub-threshold changes and using one shared palette took a 9-second clip from 15 MB to 1.2 MB.
- The daemon always renders, even headless (
enable_cameras). Without rendering, PhysX never registers a prop spawned at runtime. Prop poses are read from fabric, because the USD transform and the PhysX CPU query both stay at the spawn pose, and creating a PhysX tensor view mid-simulation crashes CUDA. - No floor for range tests (
ground=False) on anything whose links can reach the ground. Otherwise the test measures the floor, not the robot.
Development
python -m unittest discover tests   # host-side tests: no Isaac, no GPU
ruff check .
dex_isaac_mcp/protocol.Client is a handy debugging client:
from dex_isaac_mcp.protocol import Client
with Client() as c:
    print(c.call("status"))
    c.call("set_pose", name="ready"); c.call("step", n=240)
Status
Tested against Isaac Lab 2.3.2 (Isaac Sim 5.x) and mcp 2.3, over the stdio protocol, with the GUI on:
-
Franka and Allegro examples, plus a custom closed-linkage hand through a compose override:
sim_up, poses, screenshots,sim_range_test,sim_sweep(restores the original value),sim_down. -
Headless daemon: gains, frozen-parameter rejection, wave.
-
Headless capture and recording, Allegro and Franka: auto-framing, backdrop, captions, GIF output (the clip at the top).
-
Props, GUI and headless: a sphere and a cylinder dropped onto a static table settle at exactly table height plus their radius and half-height.
-
Training, against Isaac Lab's stock skrl script:
Isaac-Cartpole-v0launched, polled, logged, checkpointed and read back through everytrain_*tool, plus a run stopped mid-training. skrl'swrite_interval: autowrites no TensorBoard scalars on a very short run (5 iterations), sotrain_metricscomes back empty there; 50 iterations gives 18 tags.
Issues and PRs are welcome.
License
MIT, see LICENSE.